Zhuojie Kuang
Can you match my flow? · t = 0.00
Hi, I'm Zhuojie! I'm a 3rd year CS undergrad at UC Berkeley.
I'm currently a research intern at Robotics Center and previously did research on unified models.
I am interested in developing robots that continuously improve through real and simulated interactions, using both learned approaches (VLAs, WAMs, RL) and agentic reasoning (CaP, Agentic Robotics). I am studying to become a full-stack roboticist with knowledge of the entire stack, from actuators and control to distributed training and RL.
I'm currently looking for a research opportunity for robot learning. If you're a robotics researcher with an open project, please reach out to me at anthonykuang@berkeley.edu.
Research
All research →
Projects
All posts →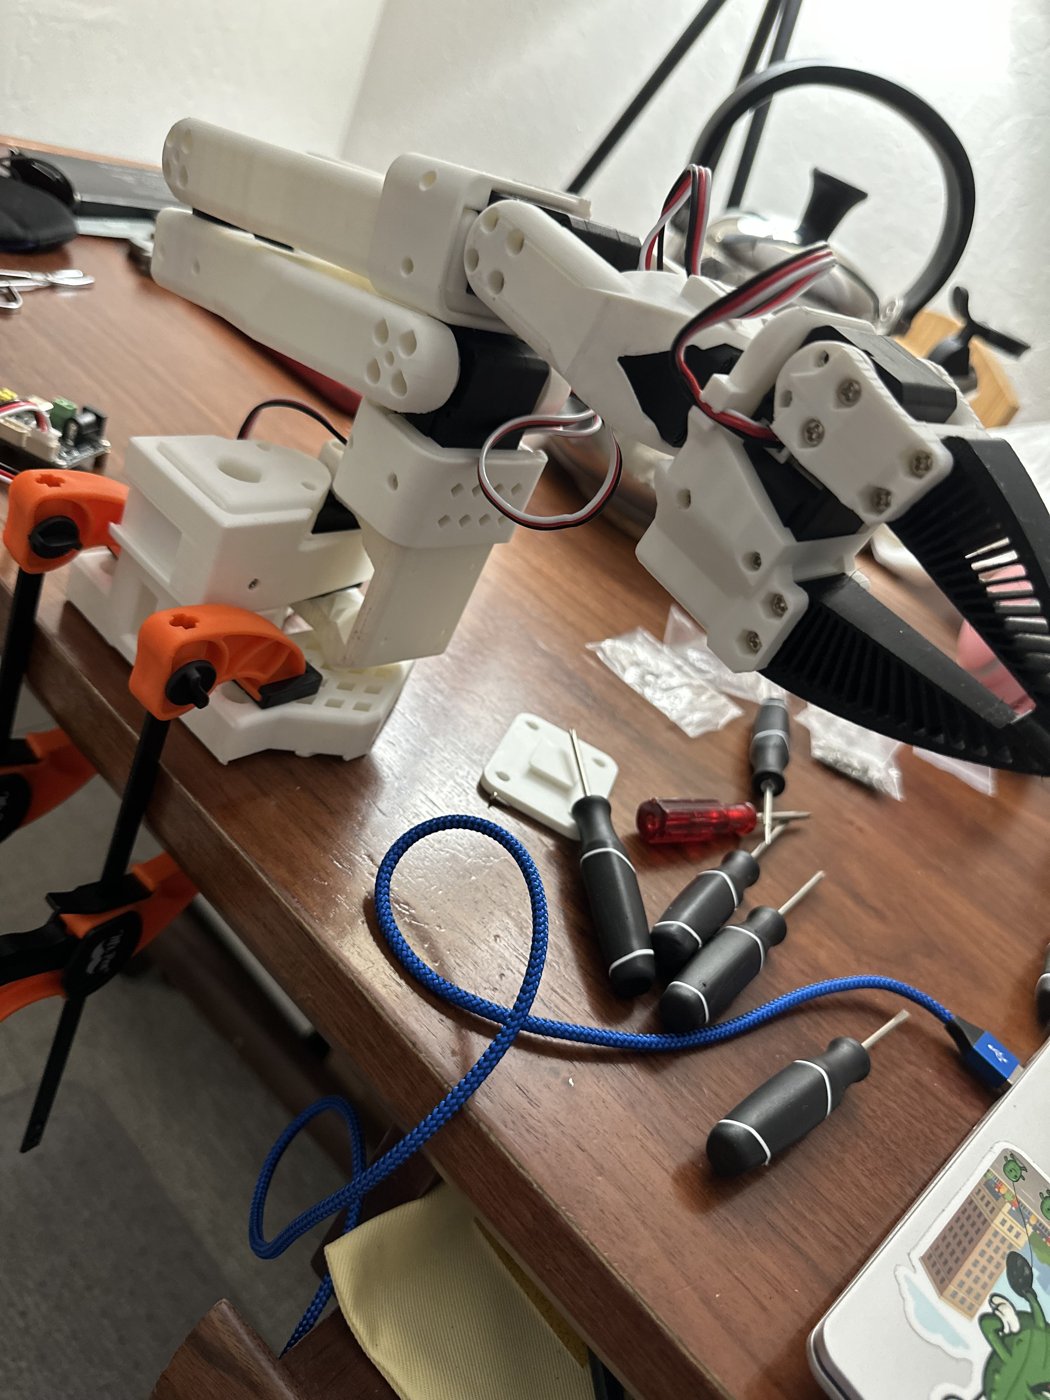
ENPIRE for SO-101
ENPIRE for SO-101.
Offline RL: SAC+BC, IQL, and flow Q-learning on OGBench
SAC+BC, IQL, and flow Q-learning on OGBench and navigation task.
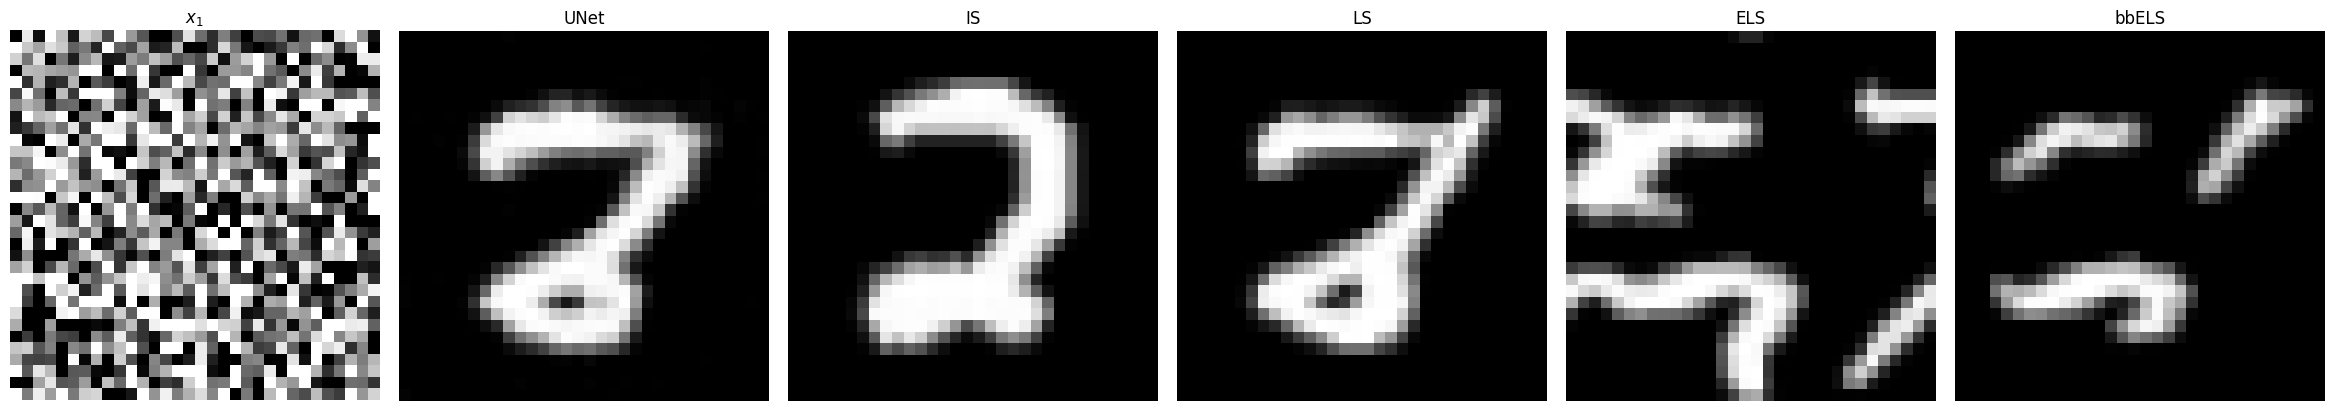
Ideal flow machines: where does a diffusion model's creativity come from?
Reimplemented and analyze analytic score machines (IS, LS, ELS, bbELS).
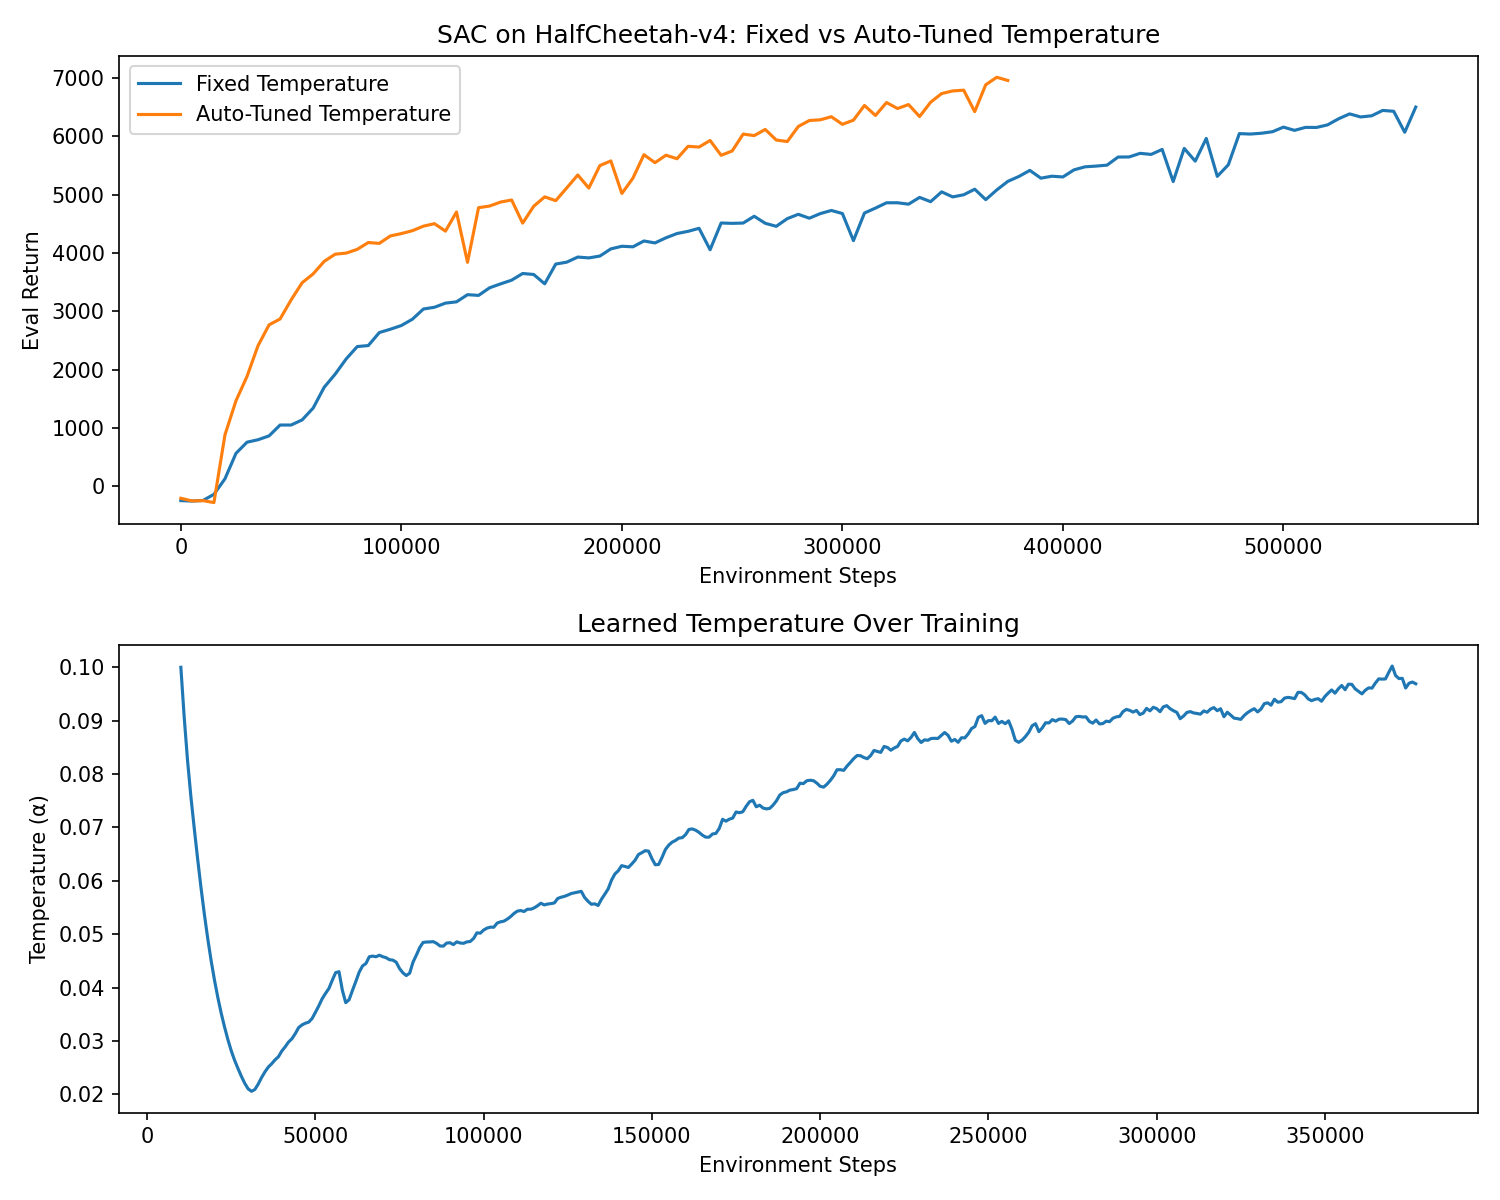
From DQN to SAC
Double DQN on CartPole, LunarLander, and MsPacman, SAC with clipped double-Q and auto-tuned temperature on HalfCheetah and Hopper.
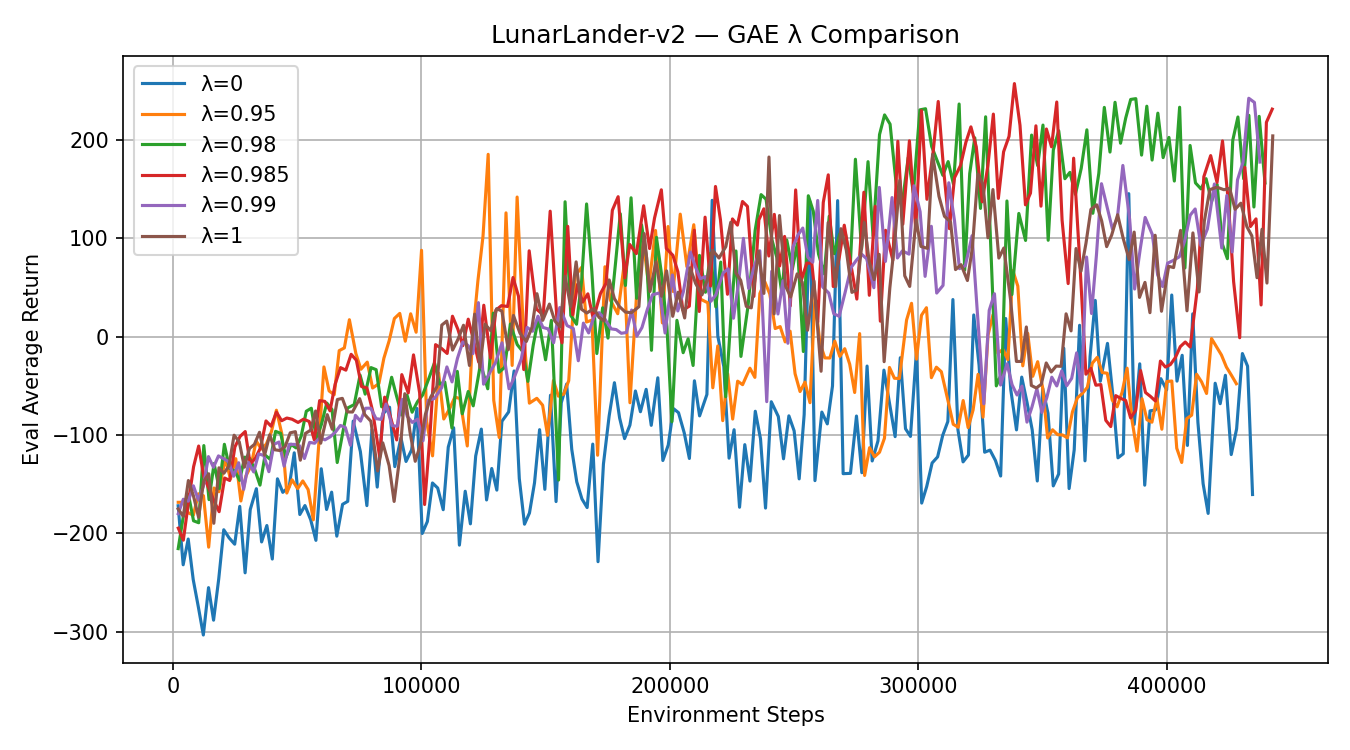
Policy gradients, one variance reduction at a time
REINFORCE on CartPole, HalfCheetah, LunarLander, and InvertedPendulum, adding reward-to-go, advantage normalization, learned baseline, and GAE.
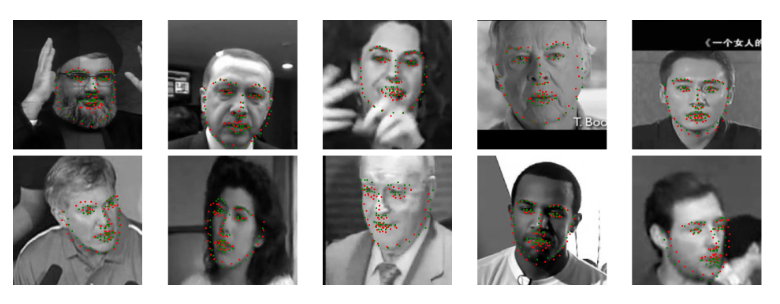
Facial keypoints: regression vs. transfer learning vs. heatmaps
Predicting 68 facial landmarks with a CNN coordinate regressor, fine-tuned ResNet-18 and DINOv2 backbones, and a U-Net outputting Gaussian heatmaps.
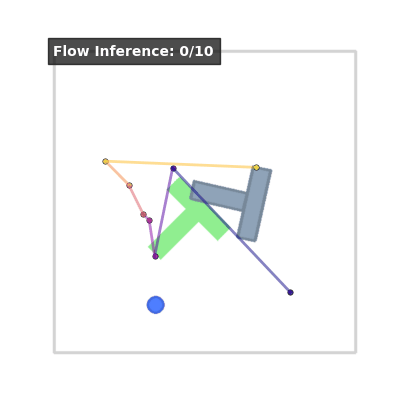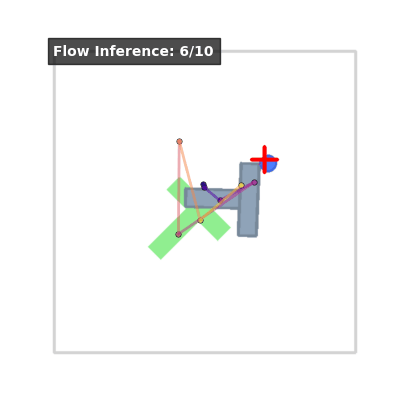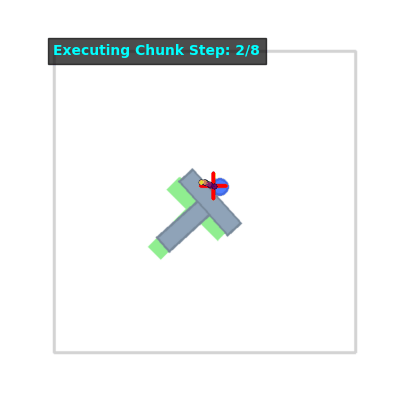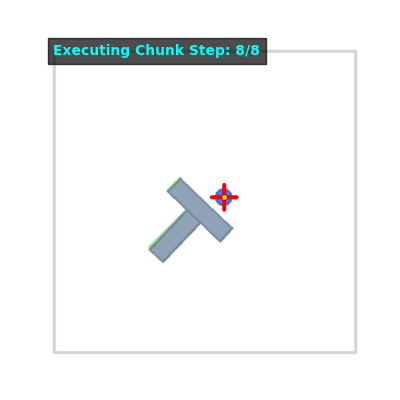
Behavioral Cloning with Flow Matching Policies
Behavior cloning on Push-T with an MSE action-chunking policy and a flow matching policy.
Miscellaneous
I am a big fan of Damian Lillard and similarly grew up in East Oakland. I sometimes enjoy playing the keyboard. I attend and help host the Saturday Robotics reading groups.